TUNCAY ÜNAL / SOFTWARE ENGINEER

SELECTED WORK · 2023—2026

Complex systems.
Considered
experiences.

I build the systems behind the interface.
And the interactions that bring them to life.

Backend & full-stack · AI-enabled applications · Real-time 3D

Explore my work
FIG. 01 / A SYSTEM IN MOTION
Connected layers of a software system: interface, services, and dataINTERFACESERVICESDATA
FROM INTERACTION TO INFRASTRUCTURE

Software engineering,
with a human perspective.

WORK ACROSSLufthansa TechnikFraunhofer CML
SCROLL TO EXPLORE

01 SELECTED WORK

Different domains.
The same curiosity.

From a webhook’s first request to a learner’s next step.
A selection of things I’ve built and the decisions behind them.

FIVE PERSPECTIVES
ON ENGINEERING
01 / BACKEND & DISTRIBUTED SYSTEMSBackend implemented

OpsReplay↗

See what changed before production broke.

A release and incident intelligence product for small engineering teams. It turns GitHub and alert webhooks into evidence-linked timelines, opens incidents from alerts, and drafts postmortems grounded in what actually changed.

GITHUB PUSH → TIMELINEArchitecture explorer
01 / VERIFY

Verify the GitHub signature before accepting the webhook. A unique delivery ID makes retries safe.

IMPLEMENTED FLOW · INSPECT EACH STAGE
Verified, idempotent webhook ingestionIncident lifecycle with change contextEvidence-grounded, versioned postmortems

Python / FastAPI / PostgreSQL / AWS SQS / OpenAI / Docker

Product UI in progress.
02 / FULL-STACK PRODUCT ENGINEERINGPrototype

A clearer
calendar.

Patient Appointment Scheduler

A full-stack scheduling prototype with month, week and list views. Relational queries keep appointments, patients and categories connected. URL-based state keeps the current view and filters intact across reloads.

THE ENGINEERING DETAIL

Three REST mutation operations, seven validated request fields, and privileged Supabase writes kept on the server.

Open the live scheduler Read the source
APPOINTMENTSOne week. In focus.
Mon
Tue
Wed
Thu
Fri
9:00
10:00
11:00

5 sample appointments · Select one to inspect

Next.js / React / TypeScript / Supabase / TanStack Query / Zod

Interactive preview · Sample data

03 / MOBILE & FULL-STACK ENGINEERINGTeam project

HairNow

From the service menu to the stylist’s inbox.

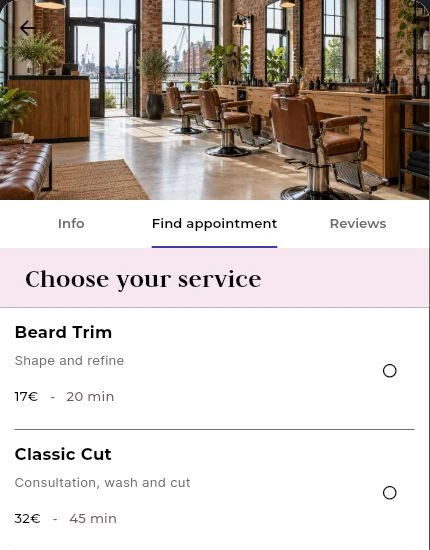
In HairNow, customers choose a service, a stylist and a time. The stylist can then confirm or decline the request. I built the overlap check and added role switching to the demo so you can try the customer, employee and salon owner views in one workspace.

Try the HairNow demo
HairNow’s service menu lists a 20-minute Beard Trim and a 45-minute Classic Cut.
CUSTOMER / CHOOSE A SERVICEThe service determines how much time to reserve with the stylist.
Full size
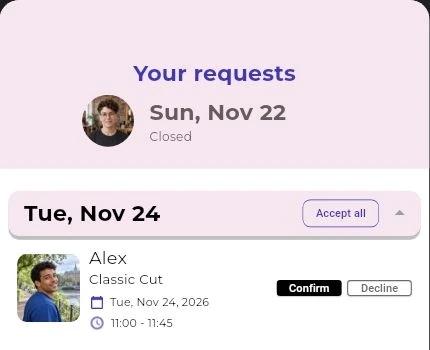
The employee inbox shows a Classic Cut from 11:00 to 11:45 with Confirm and Decline controls.
EMPLOYEE / REVIEW A REQUESTA sample Classic Cut arrives in the inbox with its start and end time.
Full size
When two requests overlap

An 11:30 trim would overlap that 11:00 cut. My booking logic checks a temporary lock for each minute of the stylist’s time. If the interval is free, one Firestore transaction writes the locks and the appointment request together.

Flutter / Dart / Firebase Authentication / Cloud Firestore

Live demo captures · Sample booking data

04 / AI, INTERACTION & RESEARCHLufthansa Technik · Master’s thesis

The right information.
At the right moment.

AI-supported cabin safety learning

A real-time VR learning system combining speech recognition, conversational tutoring, speech synthesis and visual cues. I built task progression, evaluation and recovery, then studied how progressively revealing a concept map changed the experience.

Read the research summary in my CV
PROGRESSIVE DISCLOSURE
Learning sectionConversational guidanceVisual cuesConcept mappingEvaluationTelemetryA little less at once. More when it’s needed.
ILLUSTRATION OF THE INTERACTION PRINCIPLE
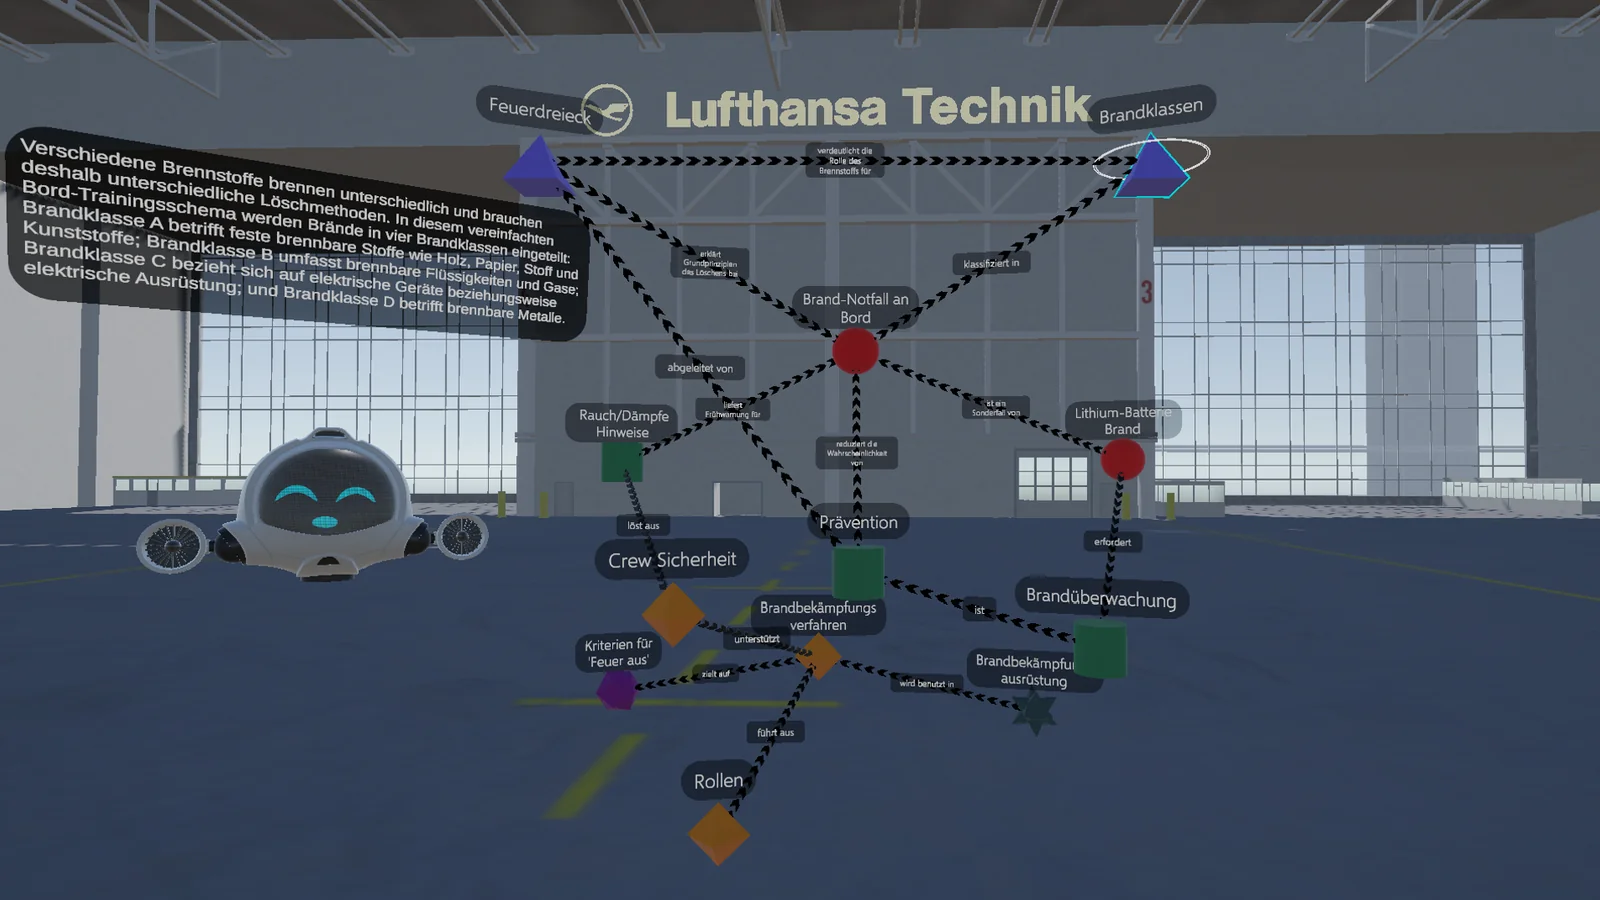
The Lufthansa Technik VR learning environment, with a conversational robot agent beside a three-dimensional concept map of cabin fire and smoke topics.
INSIDE THE IMPLEMENTED APPLICATIONThe conversational agent and spatial concept map share the learner’s environment. Actual project capture; the interactive diagram above explains the disclosure principle.
Full size
Watch the learning interaction0:21
0:21 · DEMO EXCERPTA short excerpt from the implemented VR learning flow, showing the conversational tutor and controller-based interaction with the spatial concept map.
Open video
Voice, then structure.

The agent supports conversation; the map gives that conversation a spatial structure. Learners work with nodes and connections, while task progression, evaluation and telemetry record the interaction.

The study compared progressive disclosure with full map visibility. The supplied research video reports no significant condition effect on post-test knowledge after accounting for pre-test scores.

+19.38pts

Higher mean System Usability Scale score
with progressive disclosure versus full visibility

24study participants
4,700+telemetry events
9instructional sections

Unity / C# / OpenAI integration / JSONL & CSV telemetry / HCI

Study result · 2 concept-map construction tasks

05 / REAL-TIME 3D & WEBARFraunhofer CML
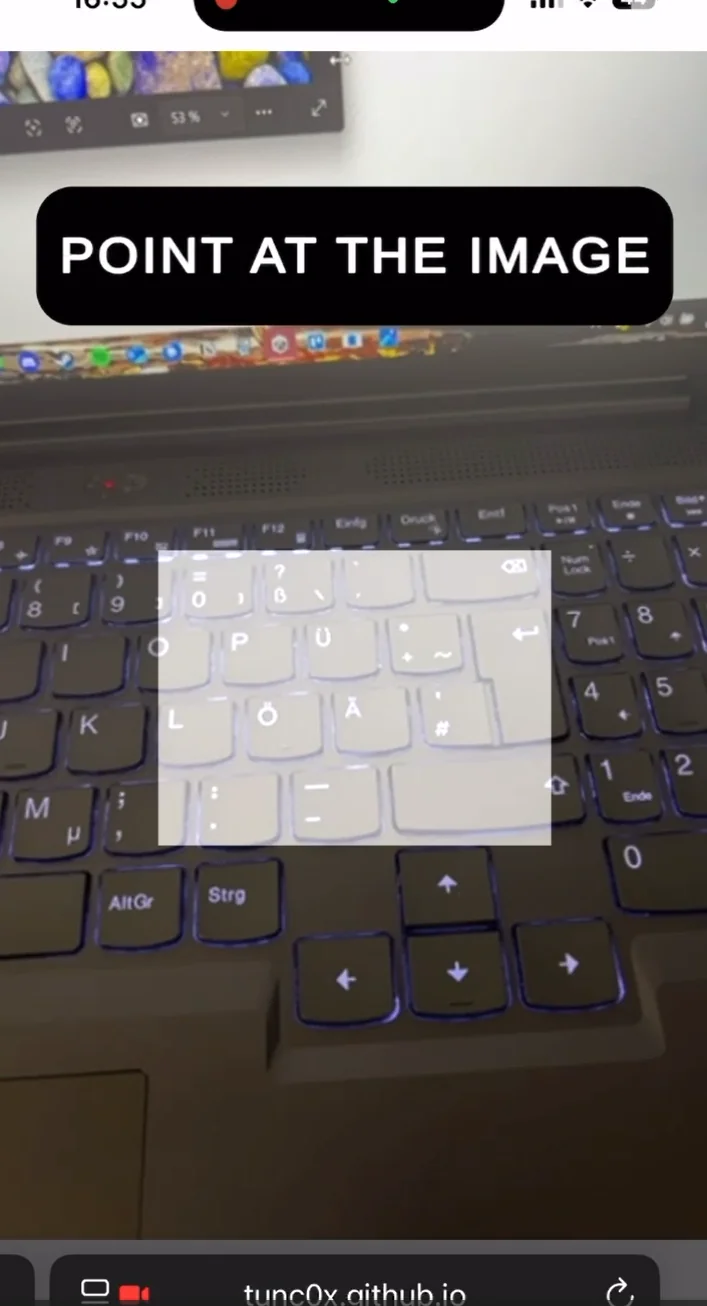
The mobile WebAR viewer prompts the user to point the camera at an image marker.
01 / FIND THE IMAGECamera input searches for the marker.
Full size
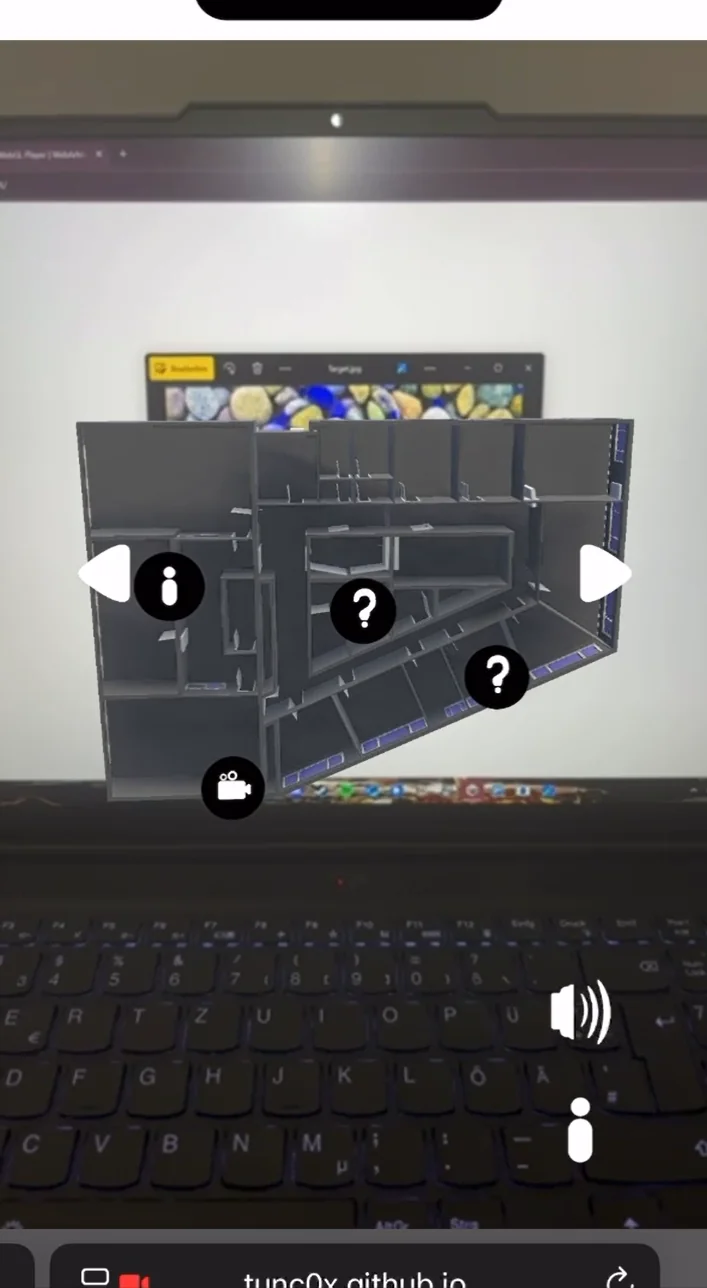
A tracked 3D building model with information hotspots appears over an image in the mobile WebAR viewer.
02 / REVEAL THE MODELThe recognised image anchors an interactive 3D model.
Full size

Software, beyond
the screen.

AR Model Viewer · Fraunhofer CML

At Fraunhofer CML, I developed and optimised Unity/C# applications for maritime and robotics R&D. My browser-based WebAR viewer connects camera access, image tracking and interactive 3D presentation.

Printed markers and business cards become anchors for a digital model in the physical world.

Inspect the WebAR build
Explore the spatial principle & demo
SPATIAL COORDINATE LABInteractive 3D
YXZLOCAL SPACE
MARKER → LOCAL SPACE → MODEL

An illustration of marker-relative positioning. No camera required.

The coordinate lab is an illustrative model. The adjacent recording shows the actual mobile application.

0:25 · DEMO EXCERPTA phone camera recognises the image on a laptop screen. A 3D building model appears over it and stays aligned as the viewing angle changes.
Open video

Unity / C# / Image tracking / WebAR / Real-time 3D

The coordinate lab illustrates the spatial principle.

FURTHER EXPLORATIONS

A wider field of view.

Robotics, physical interaction and controlled experiments.
Three more ways of making software meet the world.

06
FRAUNHOFER CML · ROBOTICS & VR

DIOR IT

Bringing a robot’s view into the headset.

Explore projectClose project
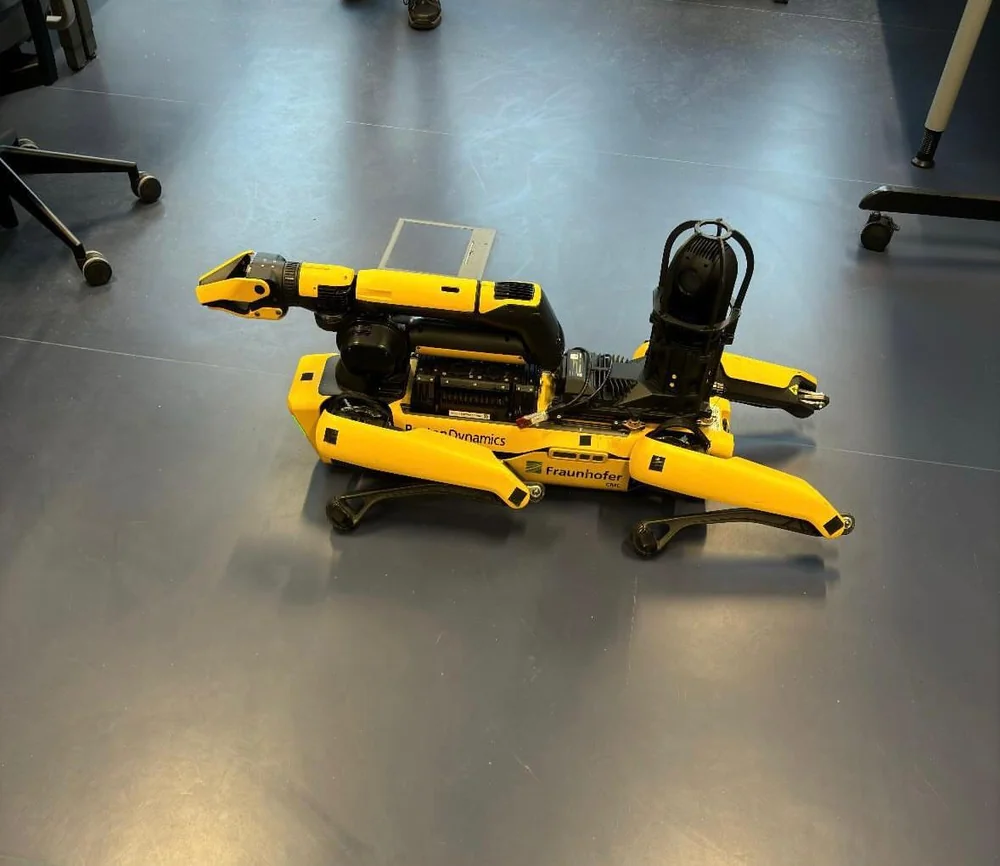
Boston Dynamics Spot with its mounted equipment at Fraunhofer CML.
THE PHYSICAL SYSTEMBoston Dynamics Spot at Fraunhofer CML.
Full size

PROJECT CONTEXT

DIOR IT explores robotics and immersive interfaces for inspection and maintenance. The wider Fraunhofer project combines remote operation of Boston Dynamics Spot, live 360° video and VR/AR tools.

My contribution

My work on DIOR IT included using the Unity WebRTC package to get the video stream working in the VR application and adding a laser marker projected onto the 360° video sphere.

WebRTC in Unity
Worked with the Unity WebRTC package to get the video stream working in the VR application.
360° interaction
Added a laser marker that projected onto the video sphere.
Explore the Fraunhofer project

Team project · Unity / C# / Unity WebRTC / 360° interaction

07
UNIVERSITY TEAM PROJECT · 2024

Bend for Your Life

Physical gestures become elemental attacks.

Explore projectClose project

GESTURE → RECOGNITION → RESPONSE

A little more movement.

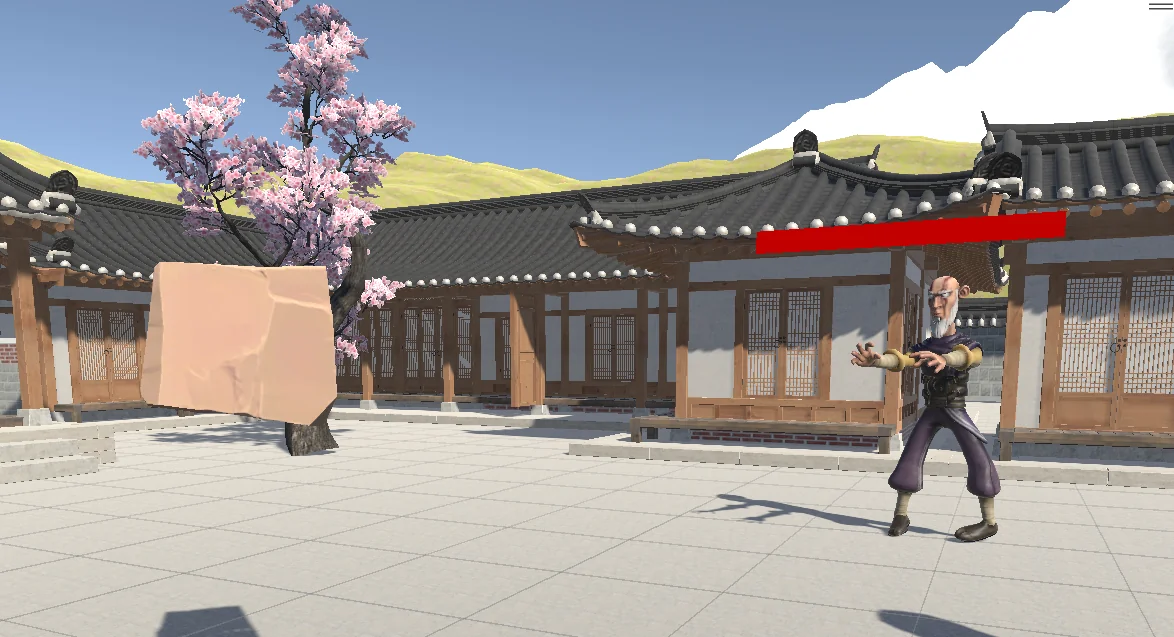
A collaborative VR exergame inspired by Avatar: The Last Airbender. Our five-person team built a Unity game for Meta Quest in which controller gestures trigger seven attacks across four elements.

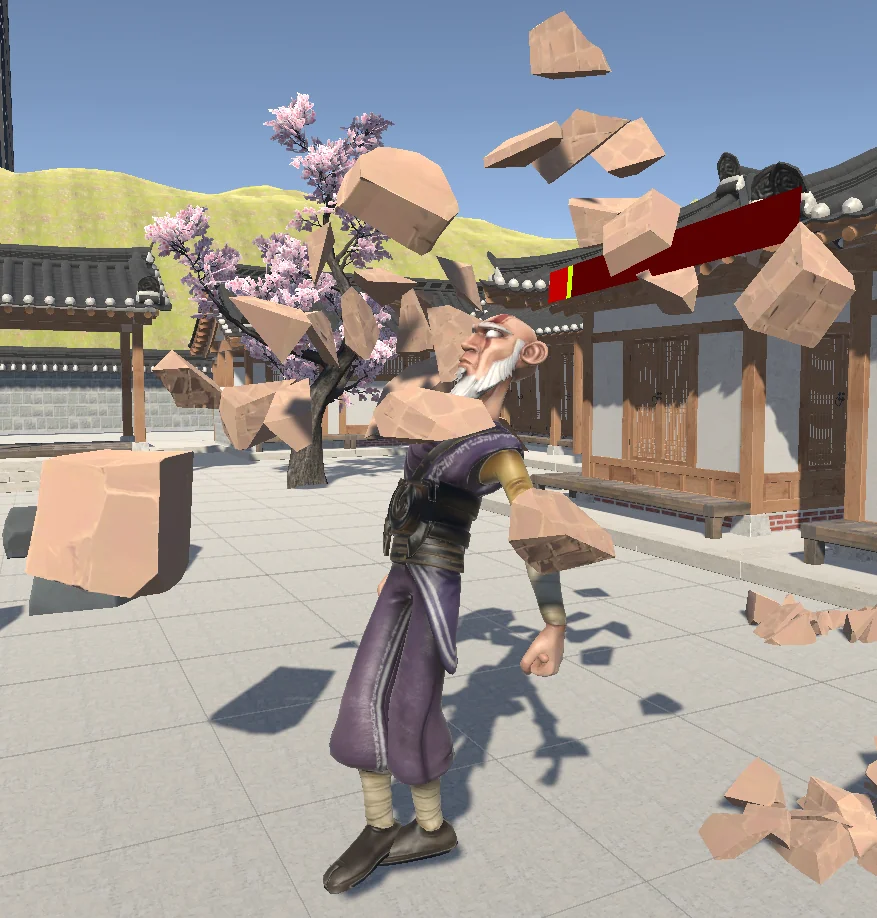
My focus was gesture recognition, enemy behaviour and destruction physics. The game matches recorded movements with MiVRy, introduces attacks progressively, and increases the opponent’s blocking and dodging capabilities across three rounds.

An earth projectile travels towards the opponent in the game's courtyard arena.
IN-GAME CAPTUREThe arena connects physical input to projectiles, enemy reactions and immediate visual feedback.
Full size
0:30 · DEMO EXCERPTThe player follows a two-handed gesture tutorial, then uses physical movements in combat. The split-screen recording connects the controller motion with its in-game result.
Open video
A rock breaks into fragments in front of the exergame opponent.
ON IMPACTRock destruction using the OpenFracture Unity package.
Full size

Built with Nazife Ertugrul, Tom Sanitz, Lara Flaig and Hauke Bünning. Visuals and mechanics shown are the team’s work, using a mix of custom and third-party assets.

University prototype · No formal user study or measured health benefit is claimed. Gesture recognition was trained by one team member, limiting its reliability across different body proportions.

08
BACHELOR’S THESIS · 2023

Street trees, mood & cognition

Four virtual streets. One controlled question.

Explore studyClose study

30 PARTICIPANTS / WITHIN-SUBJECTS DESIGN

The Influence of Street Trees
on Mood and Cognition

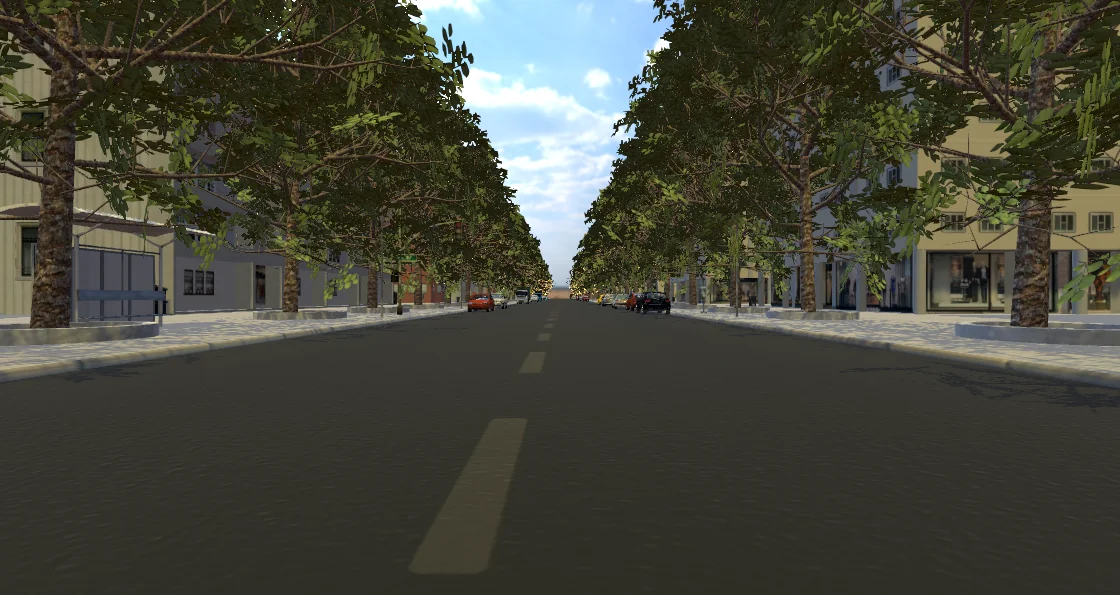
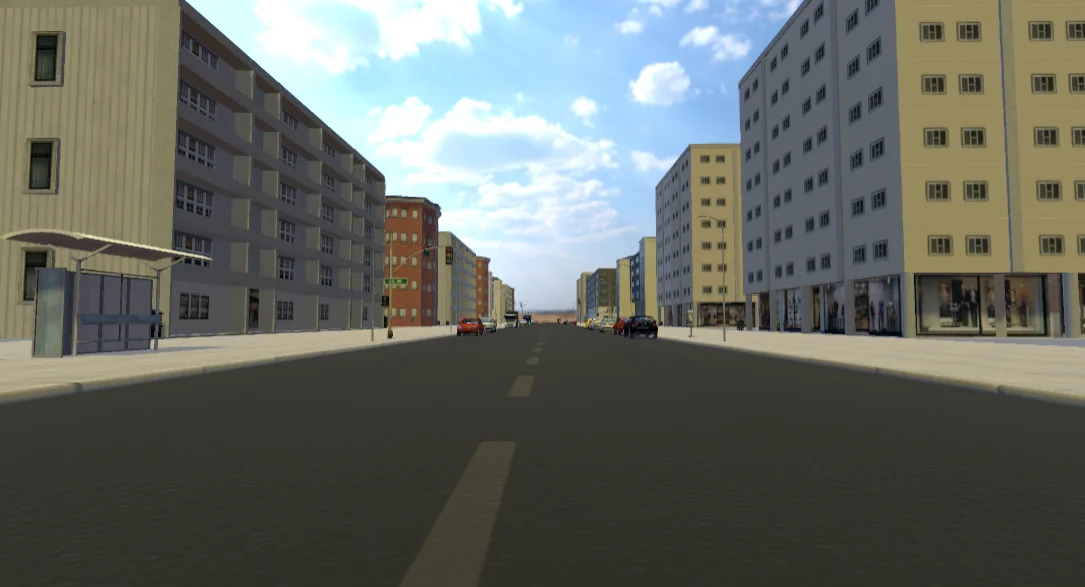
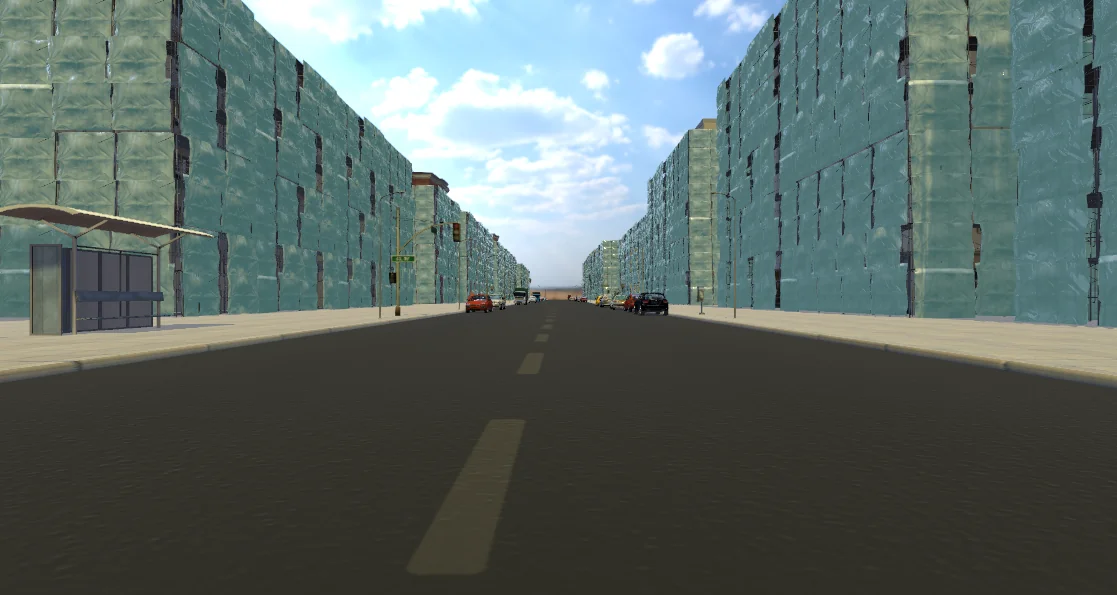
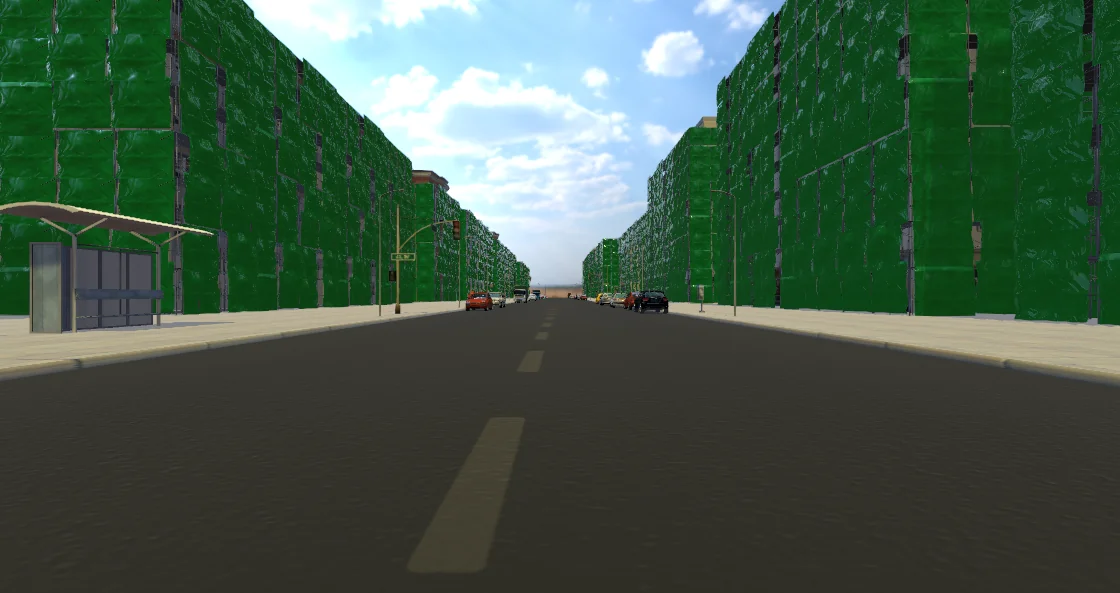
Do the effects of street trees extend beyond hiding buildings or simply adding green? I built four urban environments in Unity, keeping the street layout and background audio consistent while varying trees and façade coverings.

Each participant experienced all four scenes on an HTC Vive Pro. Passive navigation kept the route consistent; a balanced Latin square varied the presentation order. A C# digit-span task adapted from Woods et al. used researcher-scored responses.

A virtual urban street with buildings on both sides and no trees or coverings.
01 / StreetThe reference scene. Buildings remain visible.
Full size
The same virtual street with grey scaffolding covering the buildings.
02 / Neutral coveringGrey scaffolding covers the building façades.
Full size
The same virtual street with green scaffolding covering the buildings.
03 / Green coveringThe covering stays; its colour changes to green.
Full size
The same virtual street with leafy trees along both pavements.
04 / Street treesRows of trees line the same street.
Full size
Working-memory performance

Digit Span Backwards · mean span in digits

Street
5.37SD 0.96
Neutral covering
5.55SD 0.95
Green covering
5.37SD 0.96
Street trees
6.11SD 1.05

BAR SCALE: 0–7 DIGITS · N = 30

Thesis Table 4.1. Trees scored higher than each other condition in Bonferroni-adjusted paired comparisons (p ≤ .0222). Means are descriptive; the bars do not show uncertainty.

What the study found

The tree scene had higher digit-span performance and perceived restorativeness than all three alternatives. Positive affect after exposure was higher than in the plain street and green-covering scenes.

Mood change scores did not differ significantly between conditions. Neither did post-exposure negative affect. The findings therefore support a narrower conclusion than “trees improved mood.”

Measures: Digit Span Backwards, PANAS and Perceived Restorativeness Scale. Different perceived realism and coverage, a predominantly young sample, and the VR setting limit how far the results generalise.

Original title: Der Einfluss von Straßenbäumen auf die Stimmung und die Kognition: Eine Untersuchung in Virtual Reality.

02 EXPERIENCE

Built in
good company.

JAN — AUG 2026

Lufthansa Technik

Software Engineer, AI Training SystemsMaster’s thesis · Hamburg

Built and evaluated an AI-supported learning system for cabin fire-and-smoke procedures. Connected conversational interaction, concept-map tasks and detailed telemetry.

↗
SEP — NOV 2025

Lufthansa Technik

Software Engineer InternHamburg

VR Shop-Floor / Usual Suspects Training. Took internal VR training from proof of concept into deployment and trainee use.

Engineering contribution

Built reusable VR Builder behaviours and conditions. Localised subtitles and audio into English, deployed the English build for headset testing, and demonstrated XR applications at trainee and newcomer events.

Internship work, separate from the later AI-supported master’s thesis.

02
NOV 2023 — FEB 2025

Fraunhofer CML

Software EngineerHamburg

Developed Unity/C# real-time applications for maritime and robotics research, including a browser-based WebAR model viewer with image tracking.

↗

03 THE PERSON BEHIND THE CODE

A systems mindset.
A human perspective.

I’m Tuncay, a software engineer with a background in computer science and human-computer interaction.

I’m interested in both sides of a system: how it holds together underneath, and how it makes sense to the person using it. That’s taken me from aviation training and maritime research to full-stack applications and event-driven backends.

Download my résumé

Tools follow the problem.

CAPABILITIES / EVIDENCE

EDUCATION

Foundations
for the work.

2023 — 2026

MSc Computer Science

University of Hamburg

2020 — 2023

BSc Human-Computer Interaction

University of Hamburg

04 WHAT’S NEXT?

Have a system to build
or a problem worth solving?

Let’s make
it work.

Open to software engineering opportunities · UK Skilled Worker sponsorship required